← HomeAbout
Monish
Saravana
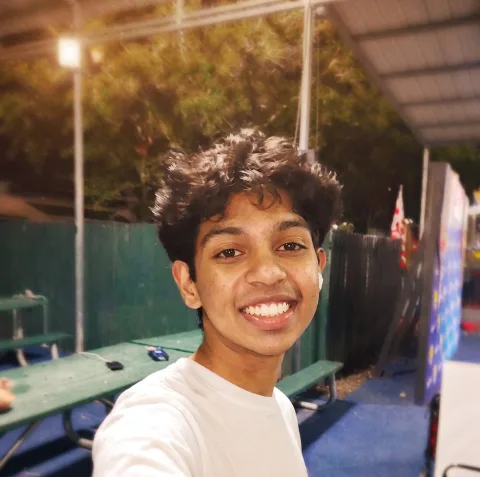
Hi! I'm Monish. I'm 18, studying Applied Math and CS at Harvard, and I love building things that sense and act in the real world. I'm especially into robotics, computer vision, and ML, and I'm also into startups and behavioral economics. I'm always happy to chat about anything, so feel free to reach out :)
- Studying
- Applied Math and CS, Harvard, Class of 2030
- Based in
- Cambridge, Massachusetts
- Working on
- Robotics, computer vision, machine learning
- Also into
- Startups and behavioral economics
What I build
S.C.O.P.E. is a perception and navigation console for Boston Dynamics Spot. You pick a target by typing a word, pointing at it, or clicking a map. Open-vocabulary detection and SAM 2.1 masks find it in a depth-built 3D map, and the robot only moves after a person confirms the plan.
LIP-TRAC is a lipreading model small enough to run on a Raspberry Pi 5. A 3D-convolutional and bidirectional-GRU network trained on BBC LRS2 transcribes speech from video alone, at 32.7% word error rate.
OCTOPAS plans where oil-spill sorbent goes from a single photo of the spill. In 60 tank trials, the same sorbents recovered 3.2 times as much oil when OCTOPAS placed them.
All of it is on the projects page.
Startups and communities
- Qurios Ventures (sciencefair.io): CMO. Helped scale the platform to $50K in monthly recurring revenue before a seven-figure acquisition.
- Claisen Health: marketing at a telehealth startup building AI-enabled, personalized gastrointestinal care.
- International Research Olympiad: helped grow a global research competition to 2,000+ participants across 85+ countries.
- FIRST Tech Challenge: teams 22012 and Vanta 31000. Built robots with control theory and sensor fusion, led the team to Worlds, and made analytics tools used by 25K+ visitors in 54+ countries.
- Harvard: involved with HFAC.
Publications
Published under my full name, Monish Saravana Kumar Divya Sundari.
- LIP-TRAC: A Lightweight CRNN for Efficient Visual Speech Recognition in Assistive Technology ↗. 2025. DOI 10.13140/RG.2.2.26136.51200
- A Novel Method for Oil Spill Cleanup Through an Optimized Pragmatic Automated System ↗. Zenodo, June 2025. DOI 10.5281/zenodo.15596105
- A Novel Method for Oil Spill Cleanup Through an Optimized Pragmatic Automated System: Year Three ↗. Florida Water Resources Journal, December 2023
Say hi
I’m always happy to talk about robotics, ML, startups, or whatever you’re working on. Email monishsaravana [at] college.harvard.edu or use the contact form.